We were introduced to hyperbolic functions in Introduction to Functions and Graphs, along with some of their basic properties. In this section, we look at differentiation and integration formulas for the hyperbolic functions and their inverses.
Derivatives and Integrals of the Hyperbolic Functions
Recall that the hyperbolic sine and hyperbolic cosine are defined as
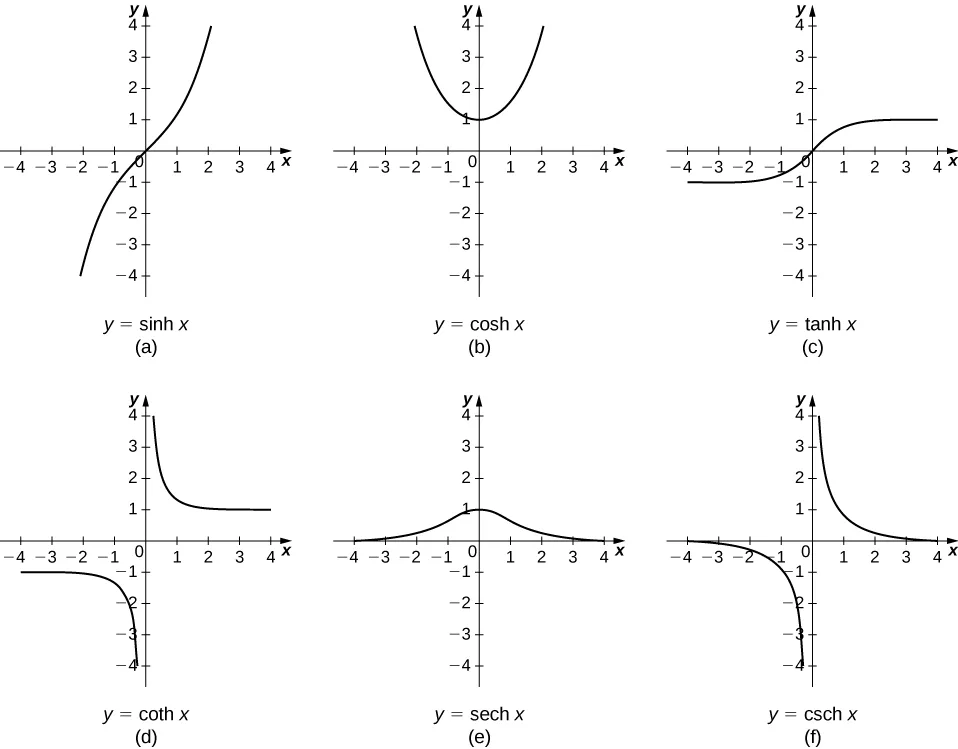
The other hyperbolic functions are then defined in terms of and The graphs of the hyperbolic functions are shown in the following figure.
It is easy to develop differentiation formulas for the hyperbolic functions. For example, looking at we have
Similarly, We summarize the differentiation formulas for the hyperbolic functions in the following table.
Let’s take a moment to compare the derivatives of the hyperbolic functions with the derivatives of the standard trigonometric functions. There are a lot of similarities, but differences as well. For example, the derivatives of the sine functions match: and The derivatives of the cosine functions, however, differ in sign: but As we continue our examination of the hyperbolic functions, we must be mindful of their similarities and differences to the standard trigonometric functions.
These differentiation formulas for the hyperbolic functions lead directly to the following integral formulas.
Calculus of Inverse Hyperbolic Functions
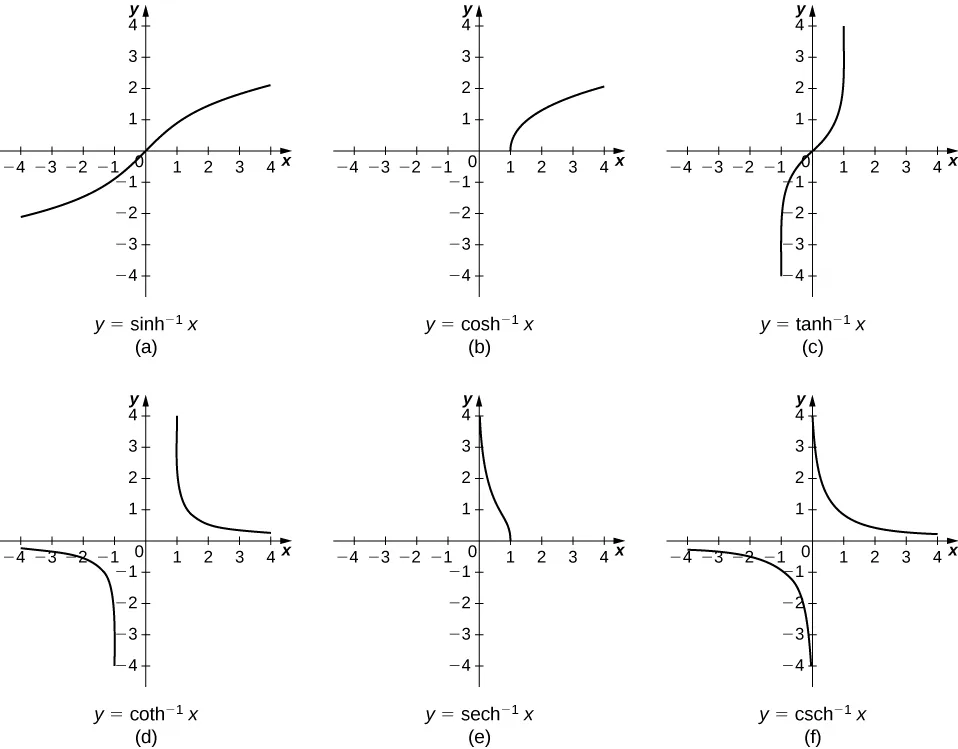
Looking at the graphs of the hyperbolic functions, we see that with appropriate range restrictions, they all have inverses. Most of the necessary range restrictions can be discerned by close examination of the graphs. The domains and ranges of the inverse hyperbolic functions are summarized in the following table.
| Function | Domain | Range |
The graphs of the inverse hyperbolic functions are shown in the following figure.
To find the derivatives of the inverse functions, we use implicit differentiation. We have
Recall that so Then,
We can derive differentiation formulas for the other inverse hyperbolic functions in a similar fashion. These differentiation formulas are summarized in the following table.
Note that the derivatives of and are the same. Thus, when we integrate we need to select the proper antiderivative based on the domain of the functions and the values of Integration formulas involving the inverse hyperbolic functions are summarized as follows.
Applications
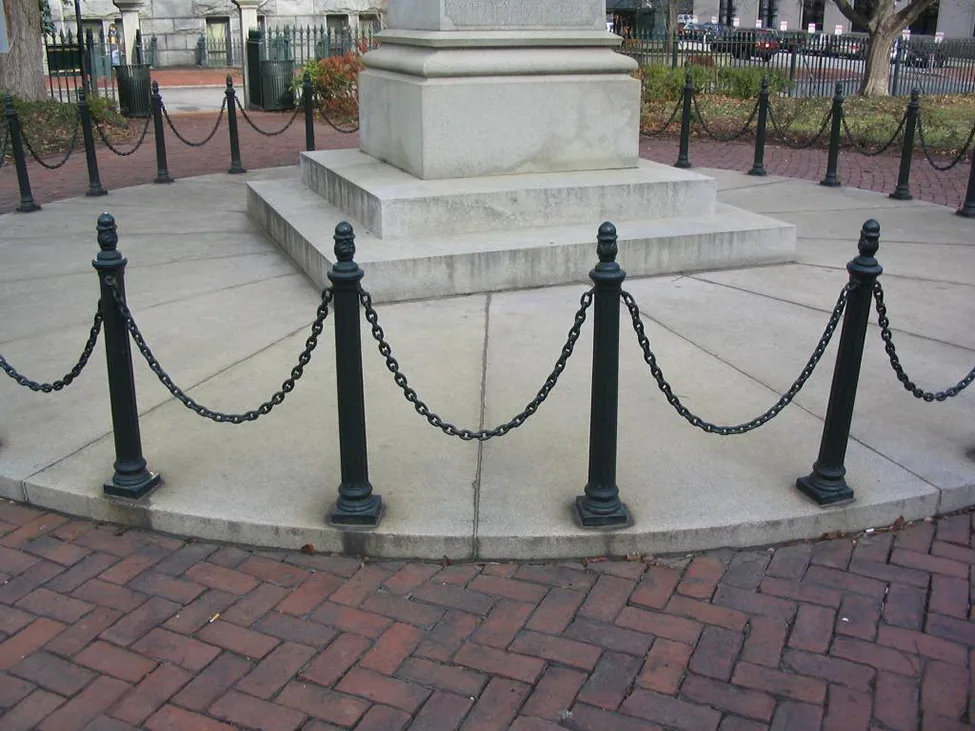
One physical application of hyperbolic functions involves hanging cables. If a cable of uniform density is suspended between two supports without any load other than its own weight, the cable forms a curve called a catenary. High-voltage power lines, chains hanging between two posts, and strands of a spider’s web all form catenaries. The following figure shows chains hanging from a row of posts.
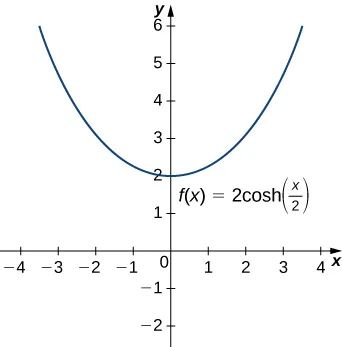
Hyperbolic functions can be used to model catenaries. Specifically, functions of the form are catenaries. Figure 6.84 shows the graph of
Key Concepts
- Hyperbolic functions are defined in terms of exponential functions.
- Term-by-term differentiation yields differentiation formulas for the hyperbolic functions. These differentiation formulas give rise, in turn, to integration formulas.
- With appropriate range restrictions, the hyperbolic functions all have inverses.
- Implicit differentiation yields differentiation formulas for the inverse hyperbolic functions, which in turn give rise to integration formulas.
- The most common physical applications of hyperbolic functions are calculations involving catenaries.